Tankline Robotics
I founded Tankline Robotics in February 2026 to automate the frac water tank line. Today, crews walk rows of frac tanks all night, reading sight glasses and cracking valves by hand. Miss a rising tank and it overflows into a spill; let one run low and the blender starves and the stage stops. Tankline builds clamp-on tank level sensors and a robot valve operator so crews get alerts before either happens.
Visit tankline-robotics→CAD animation: the tank fills, the Level Stick trips HIGH, the crew gets a phone alert, and the robot eases the fill valve closed, then reopens it as the level draws down.
Product 1 · Tank Level Stick
Tank Level Stick
Sensing
13 stainless reed float switches every 6 in (6 to 78 in) inside a perforated 3 in stilling well
Fault Detection
One-wire resistor-ladder sensing that also flags a cut or crushed cable
Controller
ESP32-S3 with LTE-M / NB-IoT cellular in an IP67 enclosure
Alarms
HIGH, HIGH-HIGH, LOW, and LOW-LOW alarms to a dashboard and phones
Mount
Clamps over the tank rim with a TIG-welded bracket, switchable magnet, and safety lanyard — no welding or drilling on rental tanks
CAD animation: Tank Level Stick, Rev A — IP67 controller, welded rim-hook bracket, switchable magnet mount, and perforated stilling well.
CAD animation: hook the rim, hand-tighten the clamp screw, switch on the magnet, clip the lanyard.
CAD animation, cutaway: floats close one by one as water rises, and the top float trips HIGH.
CAD animation: every part of the stick assembling from an exploded view.
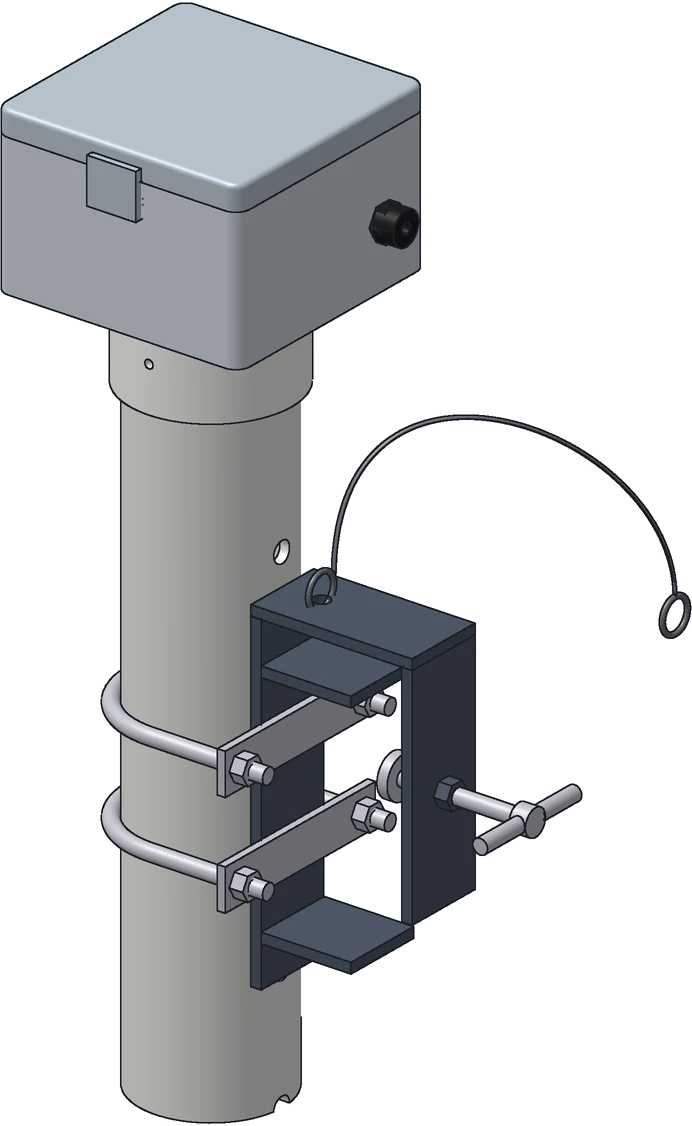
CAD model: controller, rim-hook bracket, U-bolts, and safety lanyard at the top of the well.
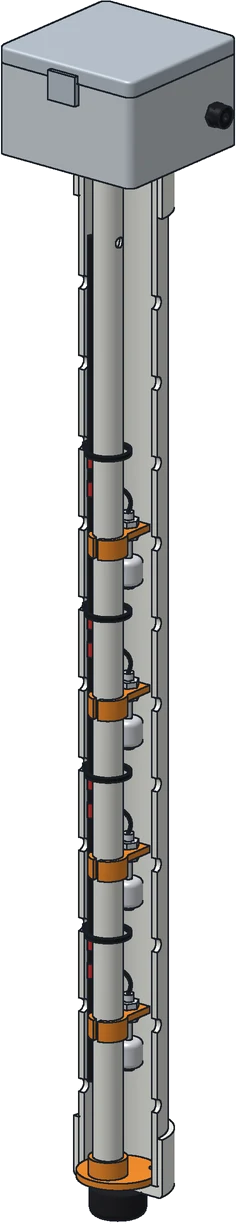
CAD model: the full-length stick with float stations inside the stilling well.
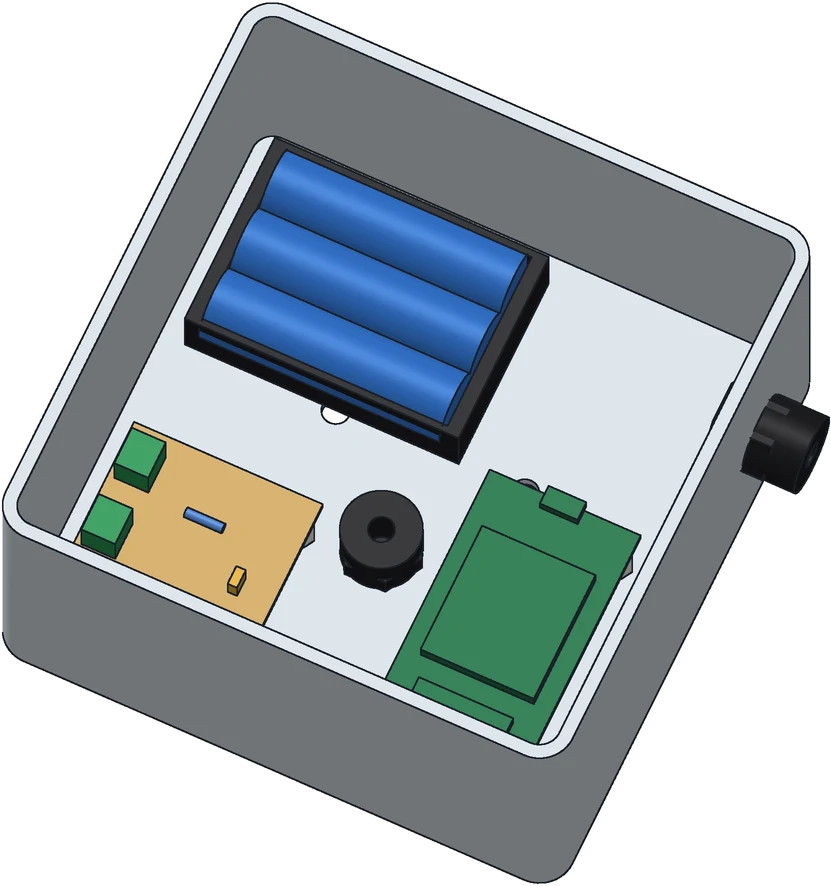
CAD model: the IP67 controller enclosure with its 18650 battery pack and electronics.
Product 2 · Robot Valve Operator (VR-200)
CAD animation: the VR-200 arm lowers onto the ball-valve lever, turns it 35° and back, and lifts off.
Robot Valve Operator (VR-200)
A 6-axis arm on the same lever-handle ball valves crews already use. It reads an inline flow meter and the level sticks and holds a flow setpoint a few degrees at a time.
It starts teleoperated, logs every session as training data, and steps up to AI control in stages.
Safety Under the Software
Hard-wired HIGH-HIGH / LOW-LOW interlocks and an E-stop sit under the software and override both the AI and the operator.
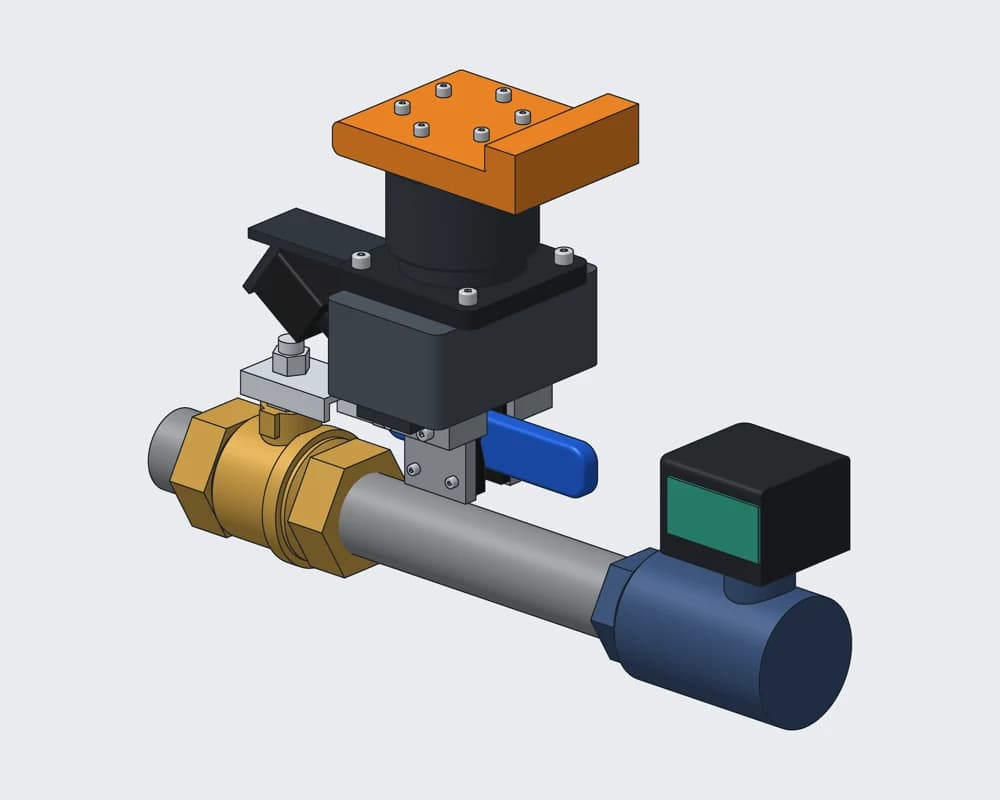
Gripper on the Lever
CAD model: V-notch pads nudge the handle a few degrees at a time.
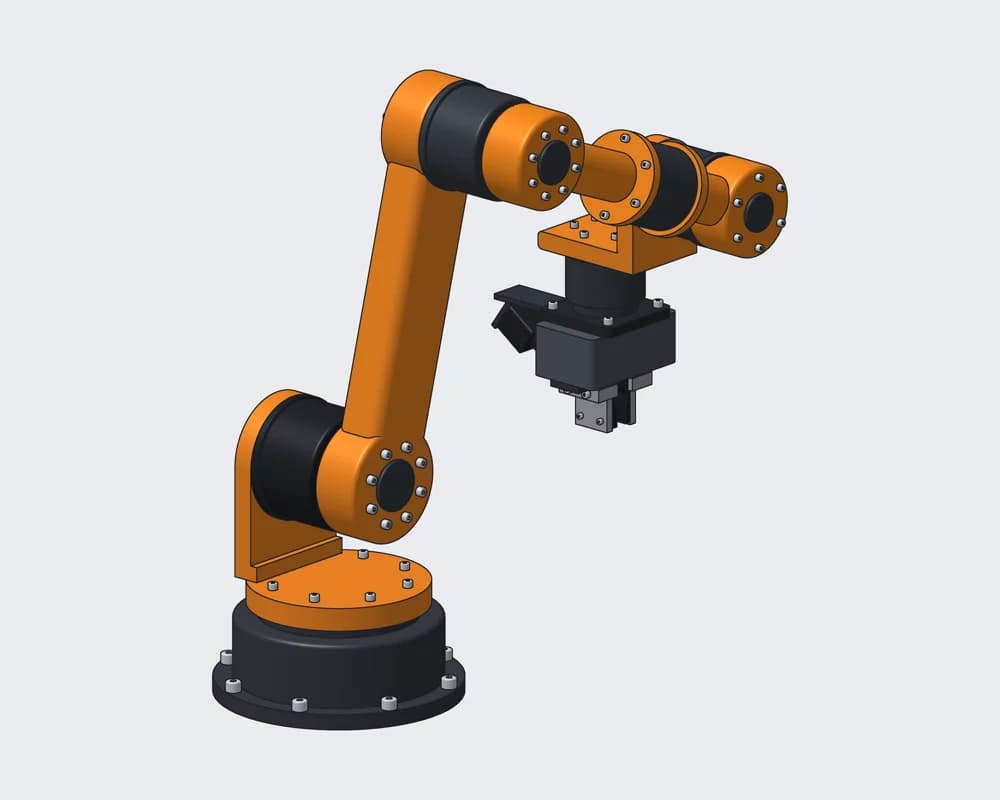
6-Axis Arm
CAD model: joint modules bolted flange to flange with machined links.
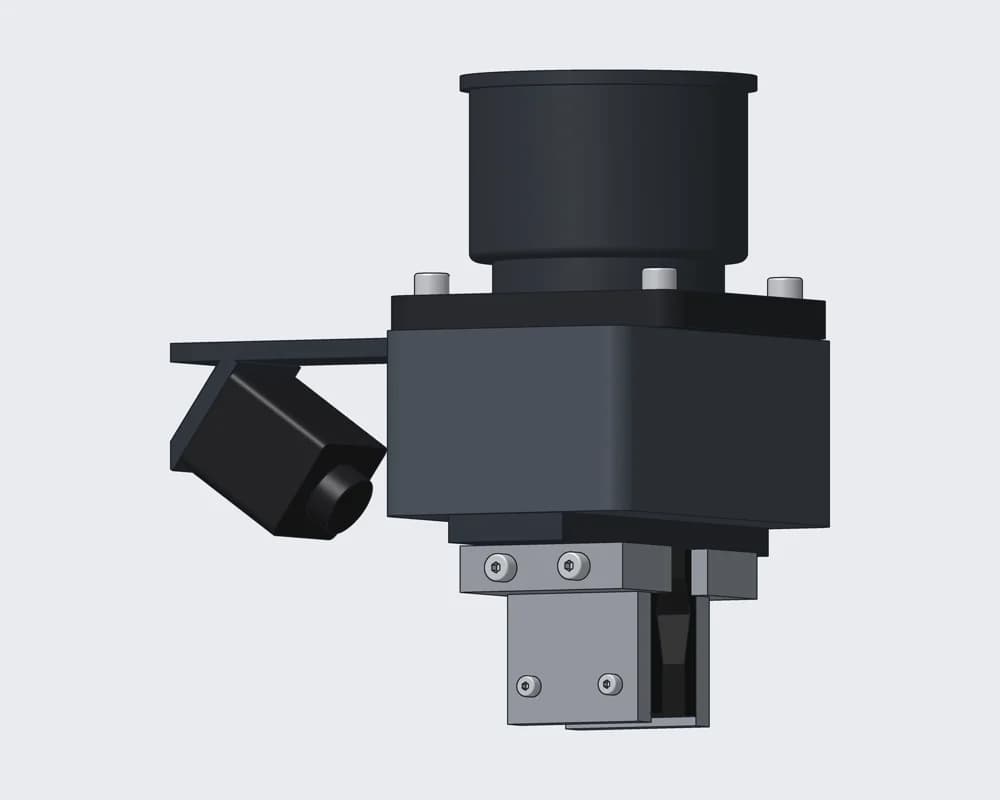
Gripper and Wrist Camera
CAD model: wrist camera angled down at the fingertips and lever.
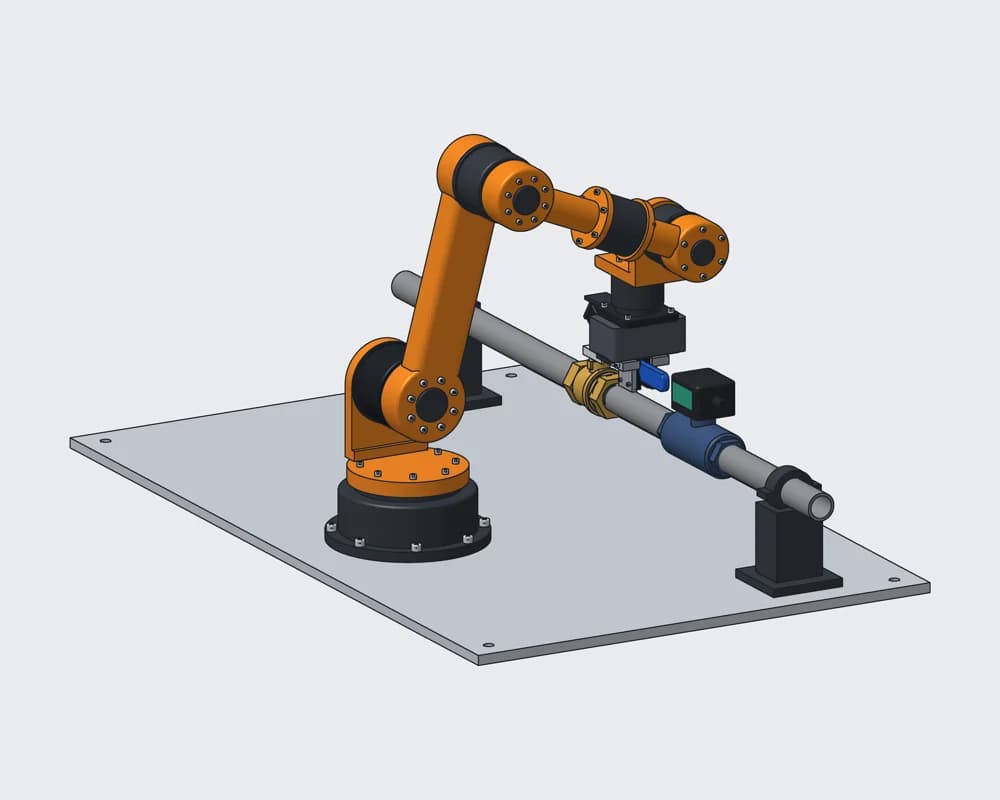
Working the Valve
CAD model: the arm reaching over the pipe to the valve lever.
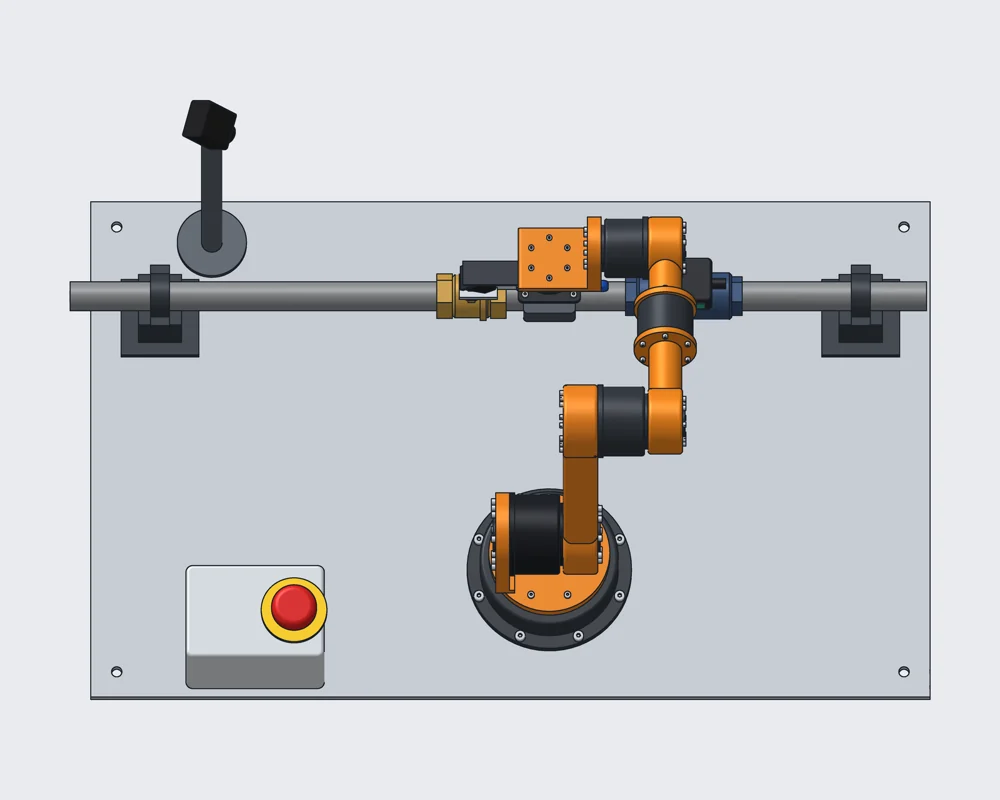
Stand Layout
CAD model: top-down view of the VR-200 test stand.
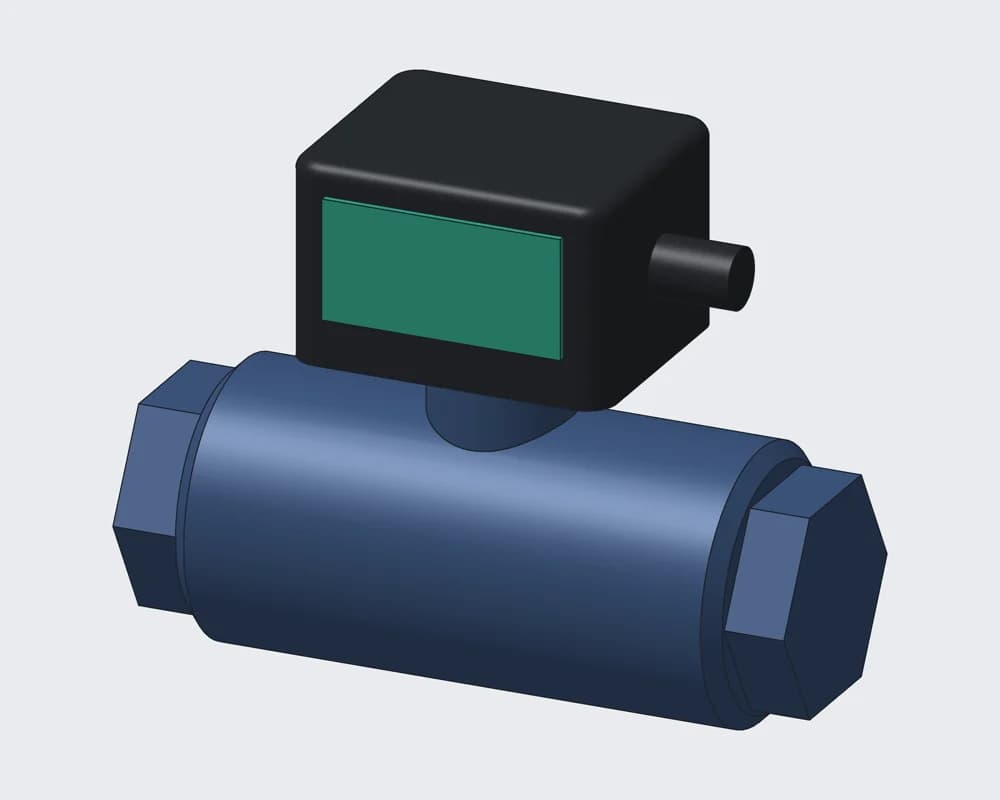
Inline Flow Meter
CAD model: the inline turbine flow meter the arm reads.
Simulated operator feeds rendered from the CAD model: wrist and overview cameras tied to live flow, valve angle, and setpoint.
Built Like Flight Hardware
Designed to the standard I worked to at SpaceX and Stoke: a full Rev A CAD model, schematic, and a 66-page build and test instruction set with inspection gates. Every unit is tested before it goes near a location.
Roadmap
01 · Sep 2026
Design complete
02 · Oct–Nov 2026
Prototype build and bench tests
03 · Dec 2026
Three field units
04 · Q1 2027
30-day pilot on real tanks
05 · 2027
Rental fleet and teleop sessions
06 · 2028
Supervised autonomy